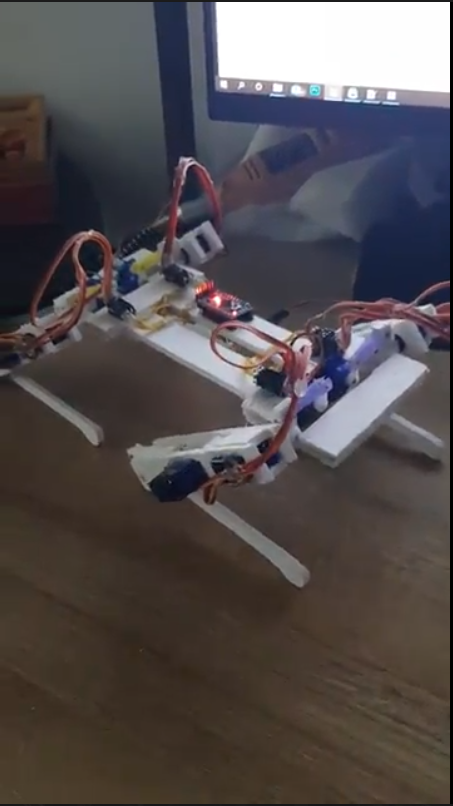
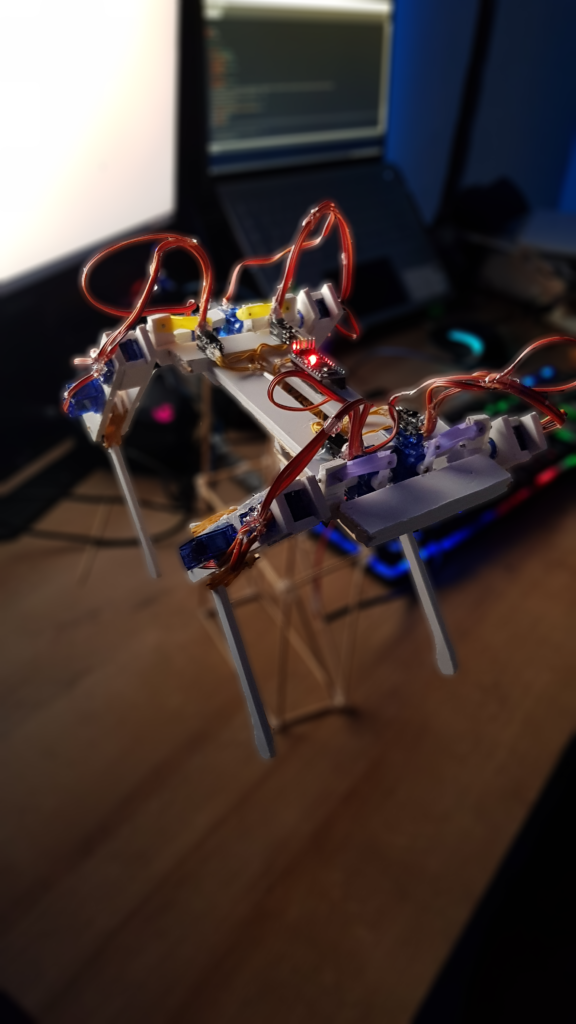
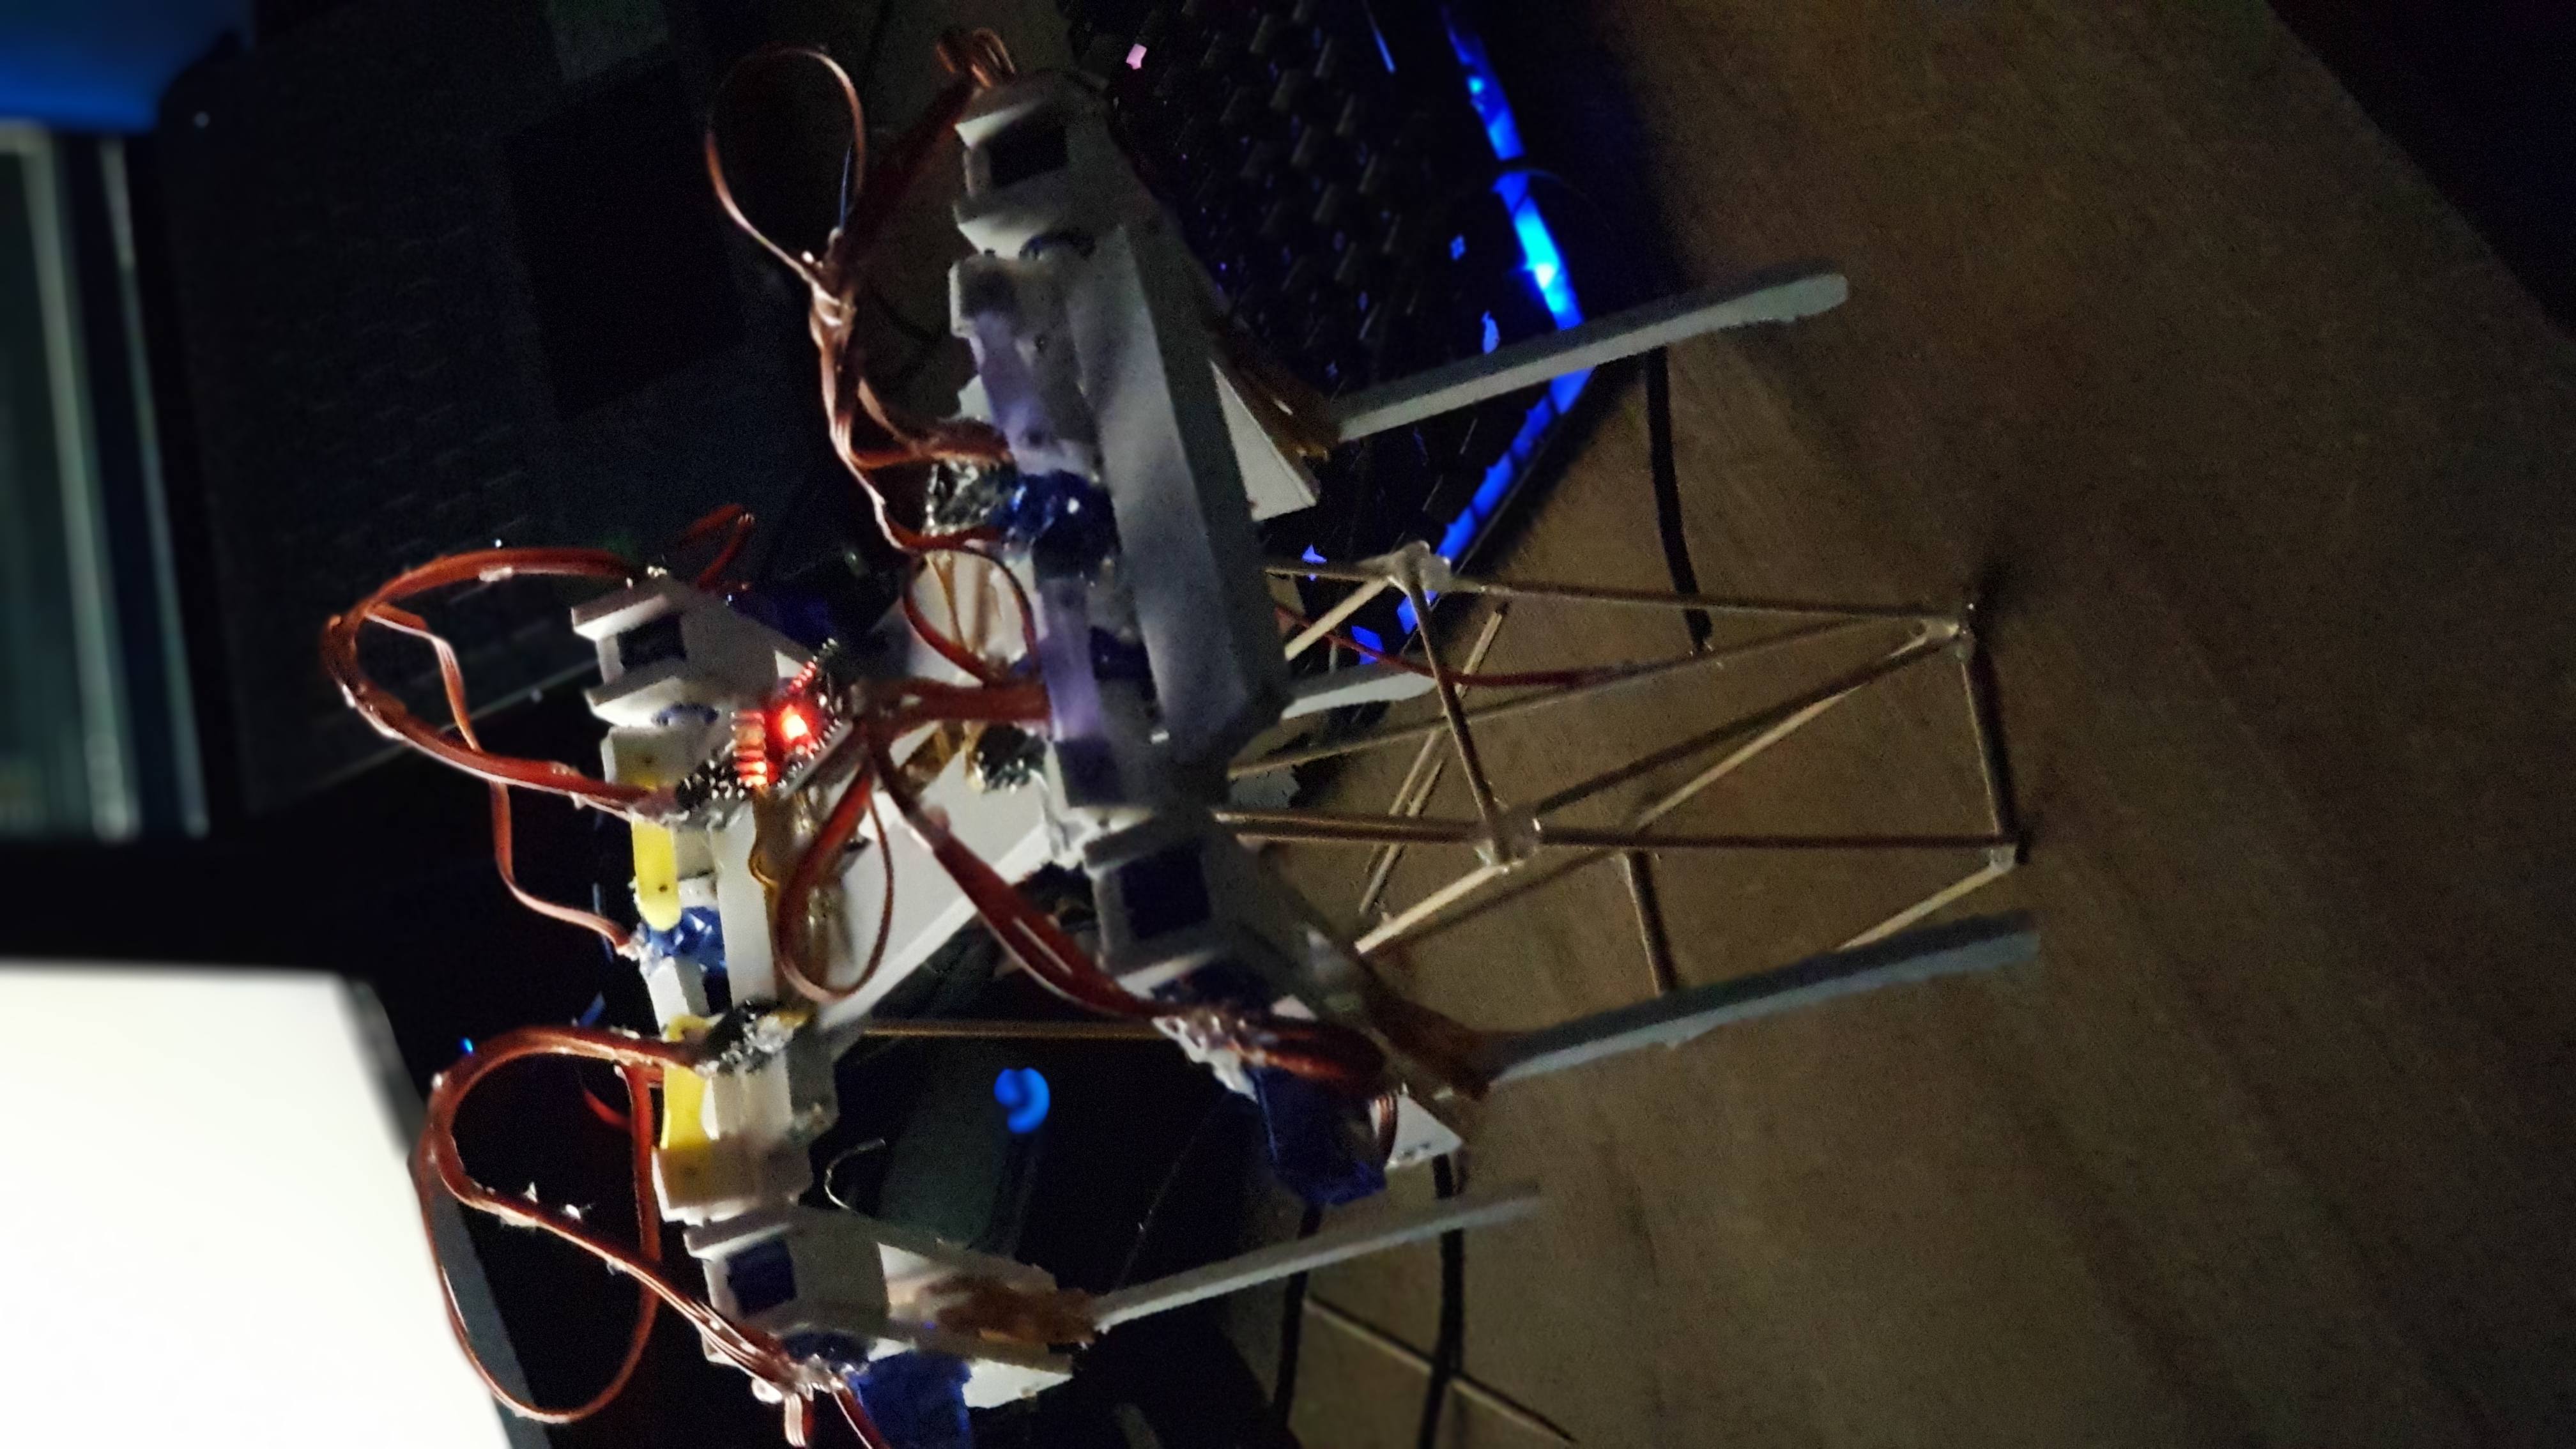
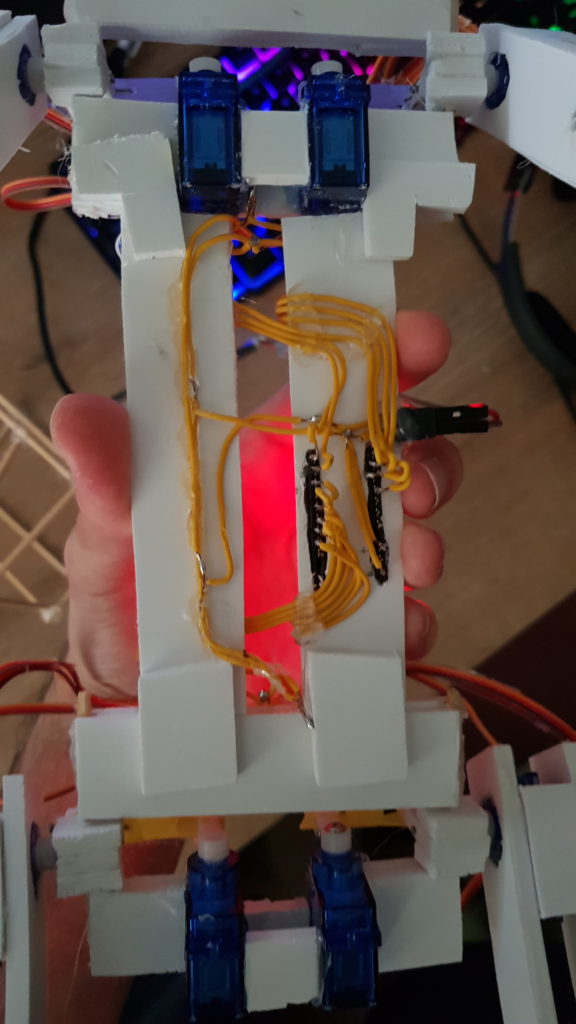
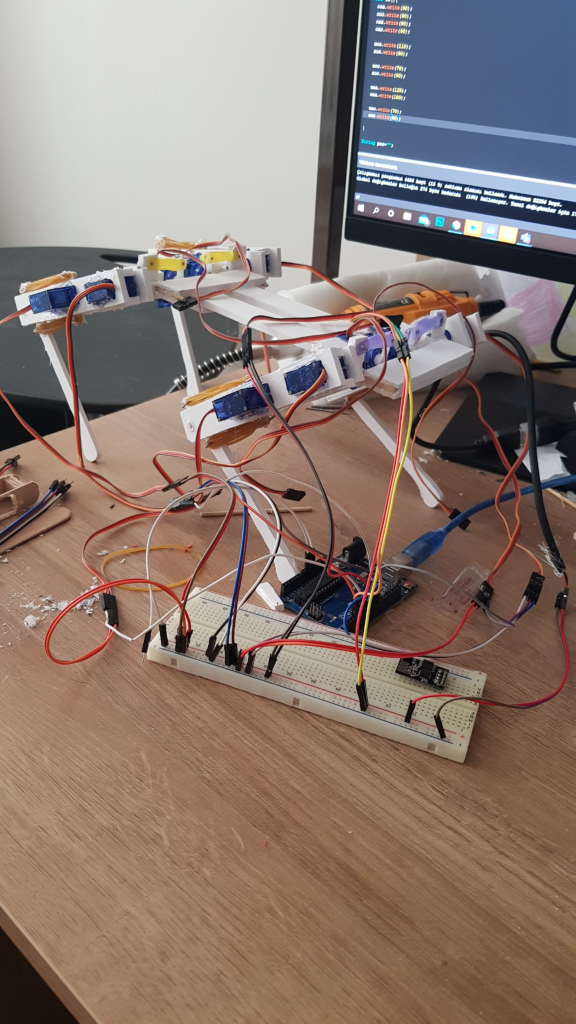
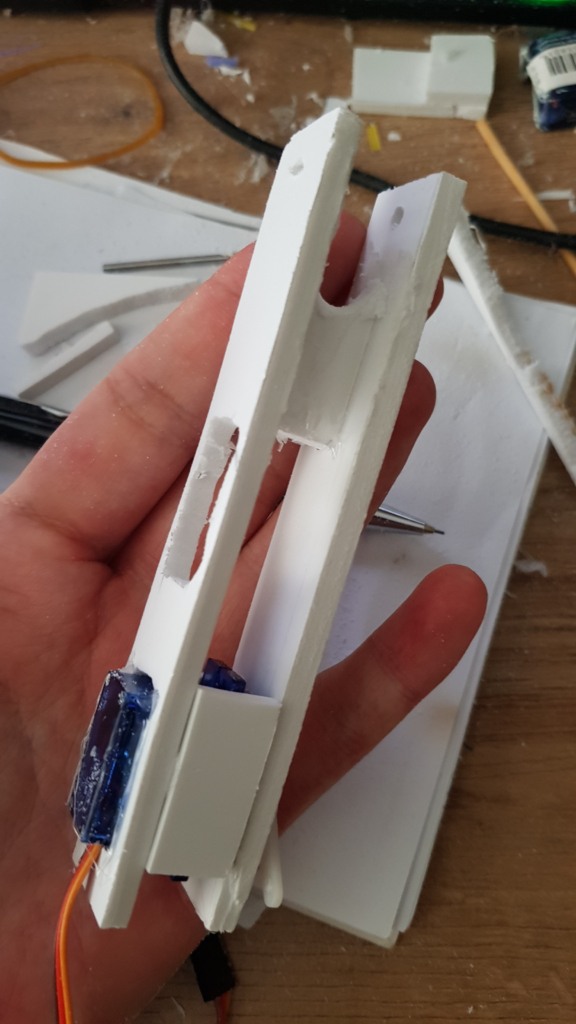
RD-03 is the third version of my independently developed quadruped platform. I formed the body and legs from lightweight plastic and rigid foam, then implemented its basic movement system with 9G servos and an Arduino Pro Mini.
The third iteration of my quadruped robot platform, using a lightweight custom body, 9G servos and an Arduino Pro Mini for foundational motion.
NEXT / RELATED WORK
Continue exploring
Drag / scroll to explore
 Robotics & Embedded Systems
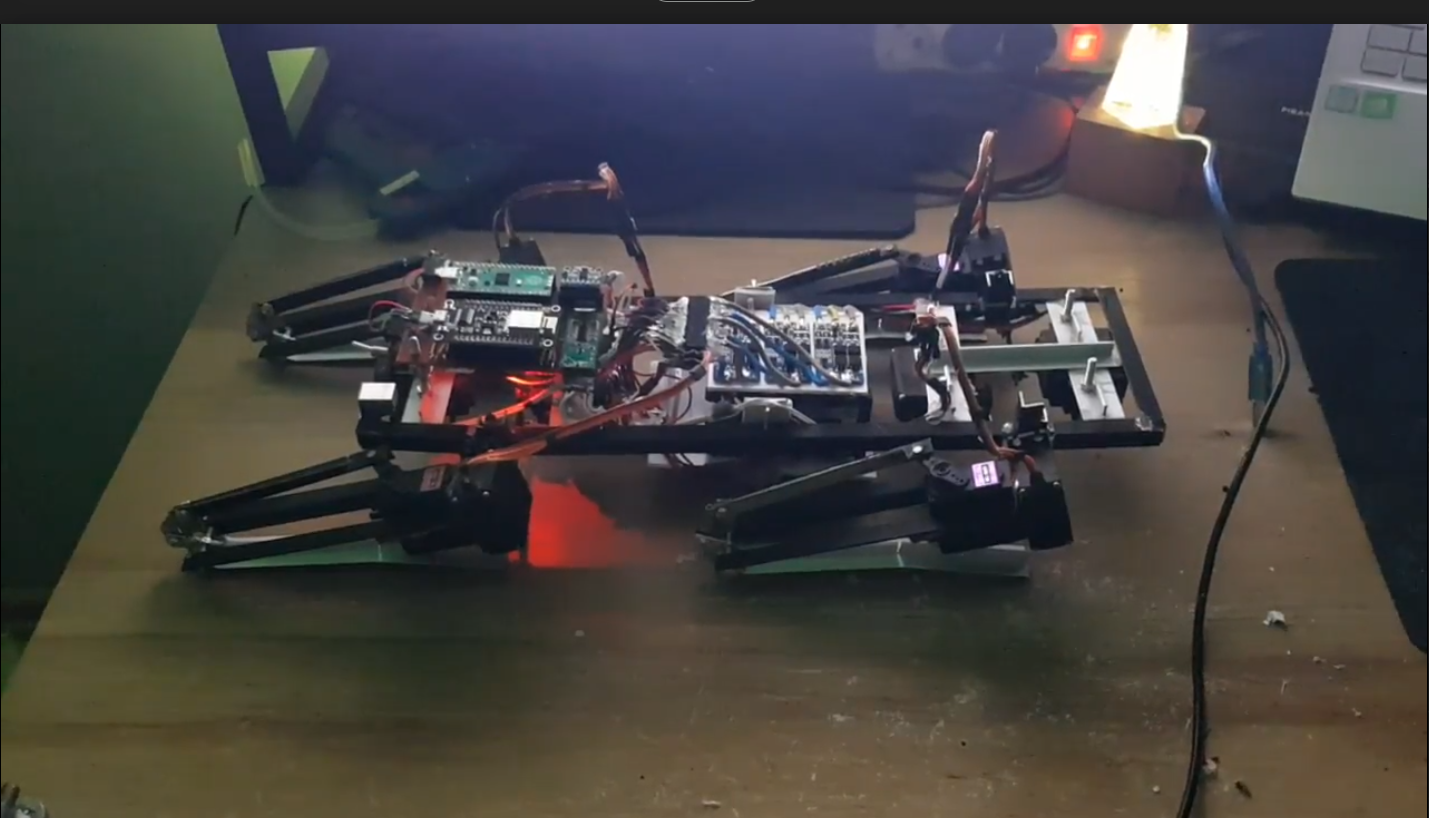
RD-04
A fully independent fourth-generation RobotDog prototype with a custom battery system, multiple microcontrollers and real-time Android control and telemetry.
QuadrupedRobotEmbeddedSystemsBatteryManagementAndroidApp
 Robotics & Embedded Systems
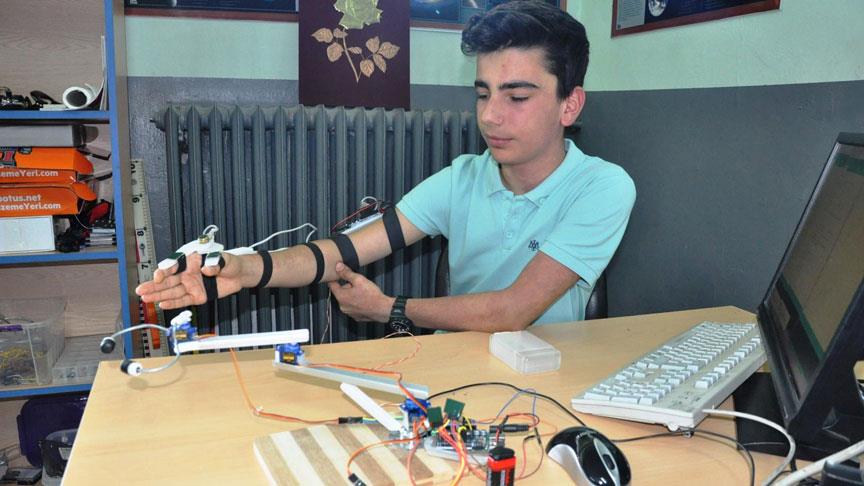
Robot Arm — TÜBİTAK High School Science Fair
A remotely operated gripping robot arm controlled through a custom wearable interface and developed for a TÜBİTAK science fair.
ArduinoC++Robot ArmWearable Device
 Robotics & Embedded Systems
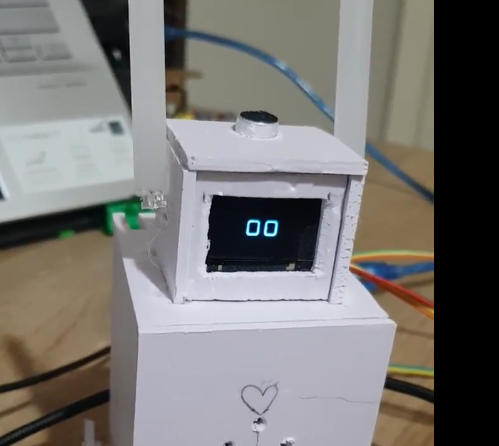
MiniRobo — Arduino Mini Robot with Expressive Face and Audio
An interactive Arduino toy robot for children, combining independent movement, audio recording and animated facial expressions.
ArduinoC++OLED LCDServo Motor
 Robotics & Embedded Systems
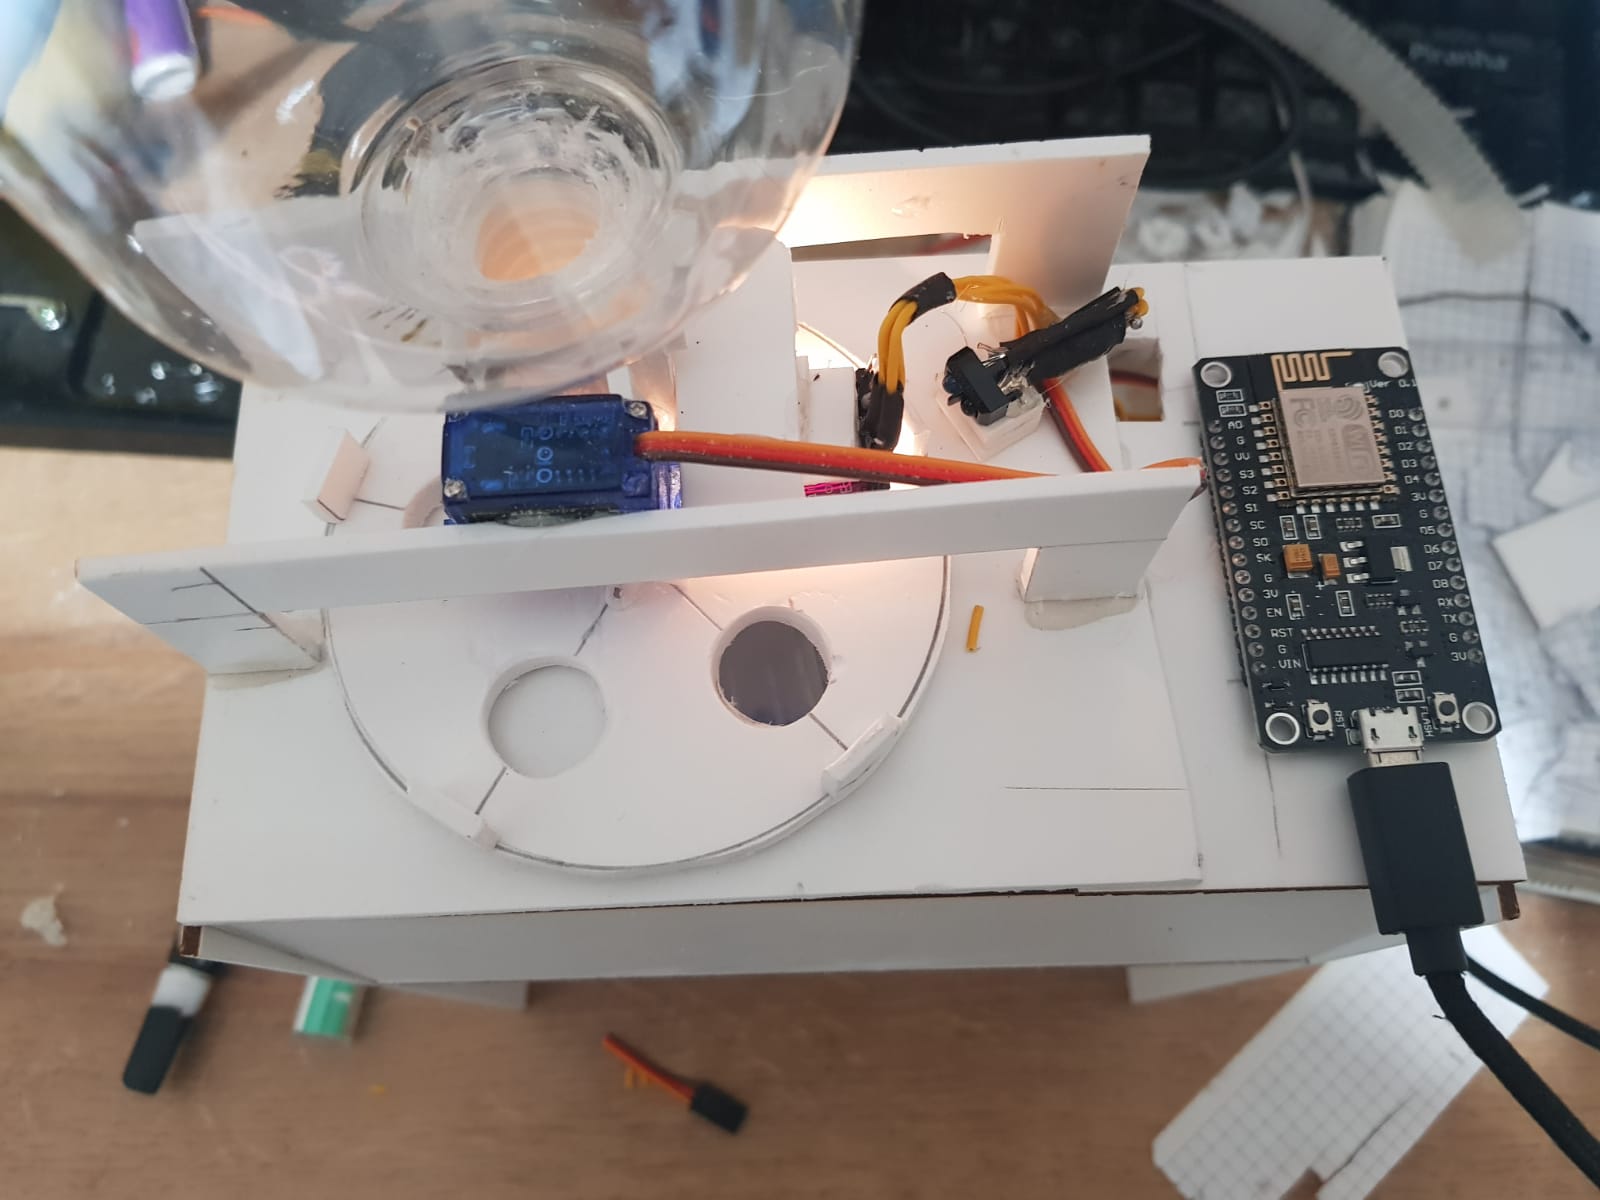
Color Separator
An ESP8266-controlled automation machine that detects colored objects and routes them into the correct compartments.
ESP8266UnityBlenderGömülü Sistemler