 Artificial Intelligence
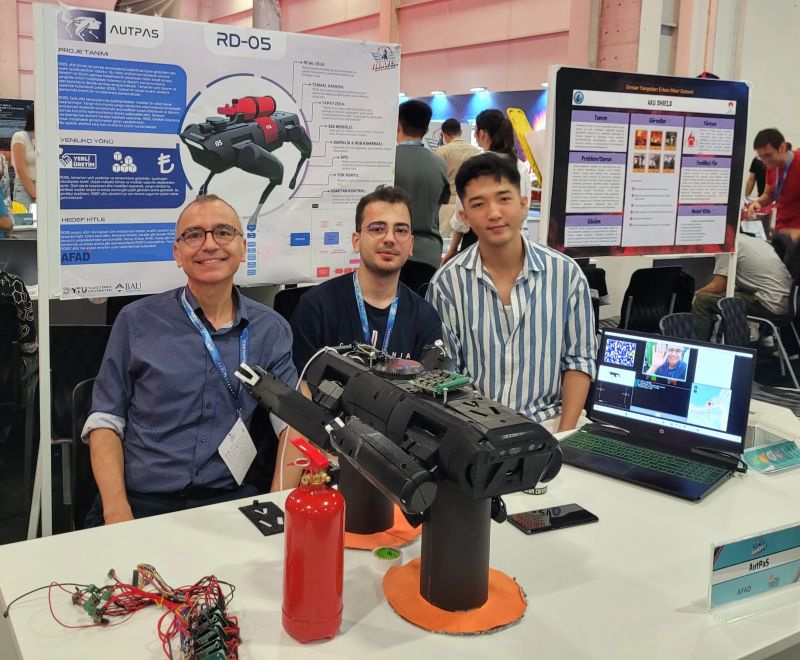
RD-05
An original quadruped robot platform I designed from mechanics to software and led technically, reaching the top 15 in the Teknofest Disaster category.
RoboticsEmbedded SystemsAI IntegrationRemote Control
I see a robot as one intelligent system — mechanics, electronics and software designed together.
My vision is to combine purposeful mechanical design with embedded control, perception and AI. Every layer should strengthen the next: a body built for the task, reliable electronics, and intelligence that turns sensing into deliberate motion.
Explore 9 projects ↓
Use the arrows, keyboard, trackpad or touch to move through the complete collection.
Artificial Intelligence
An original quadruped robot platform I designed from mechanics to software and led technically, reaching the top 15 in the Teknofest Disaster category.
 Artificial Intelligence
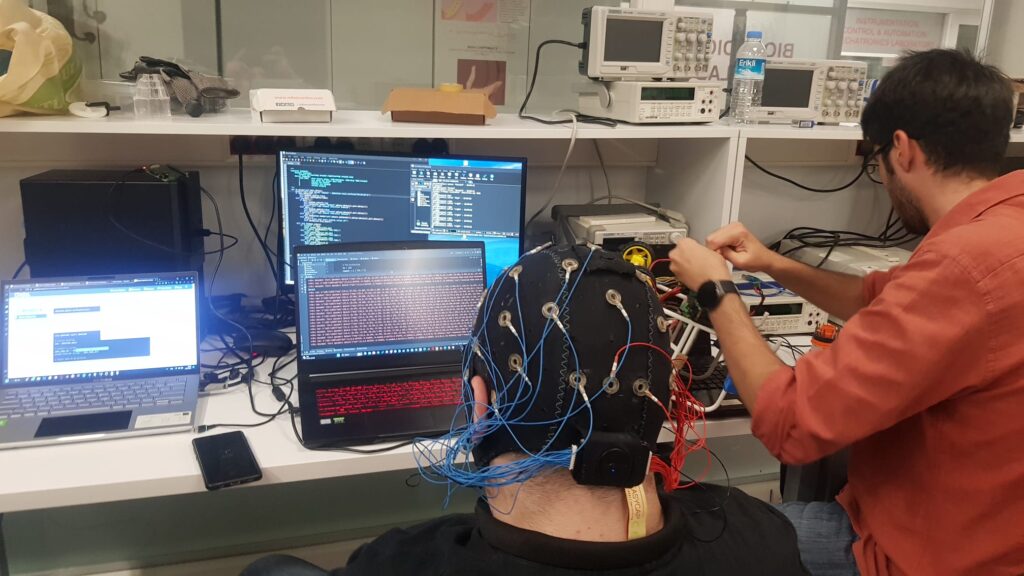
A wheelchair prototype that uses an AI model to analyze EEG brain signals and translate the user’s mental commands into directional control.
 Artificial Intelligence
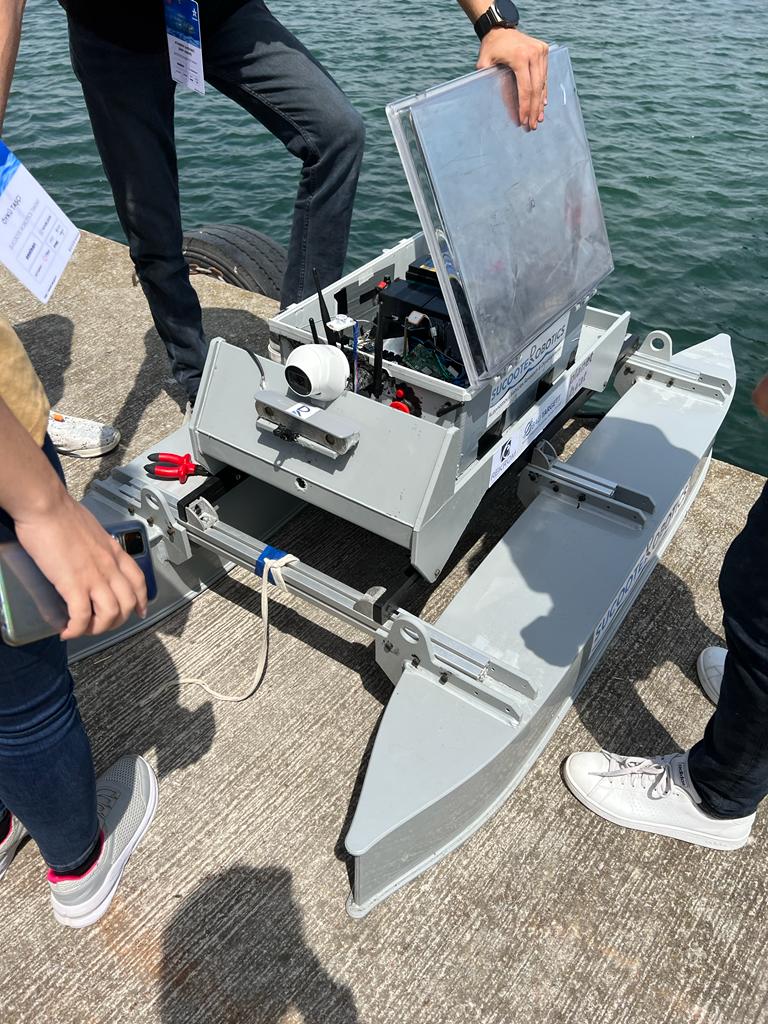
Led the software development for an autonomous surface vehicle in a nationally recognized defense industry competition, achieving 4th place. Managed full software architecture, including embedded systems and…
 Robotics & Embedded Systems
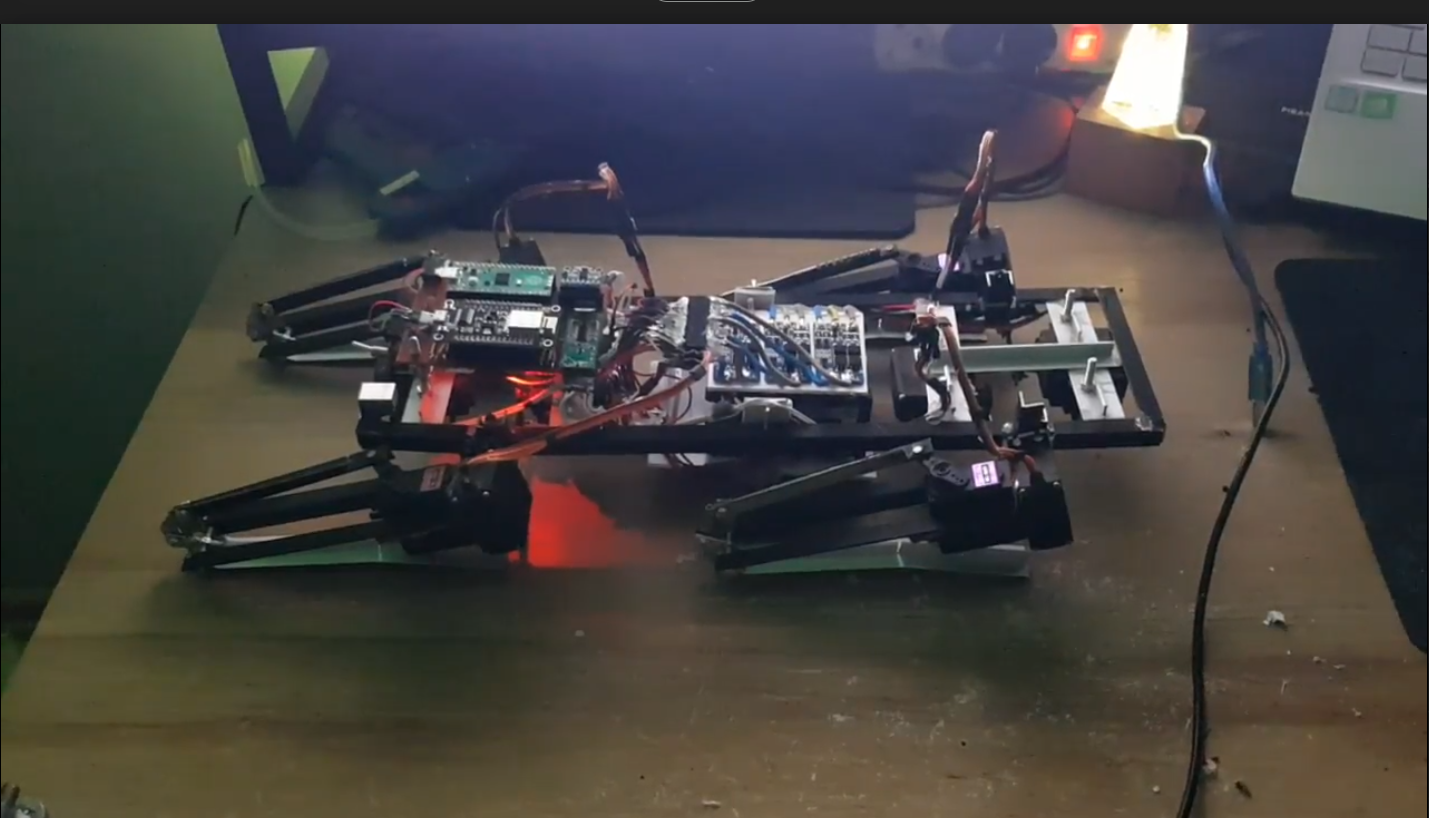
A fully independent fourth-generation RobotDog prototype with a custom battery system, multiple microcontrollers and real-time Android control and telemetry.
 Robotics & Embedded Systems
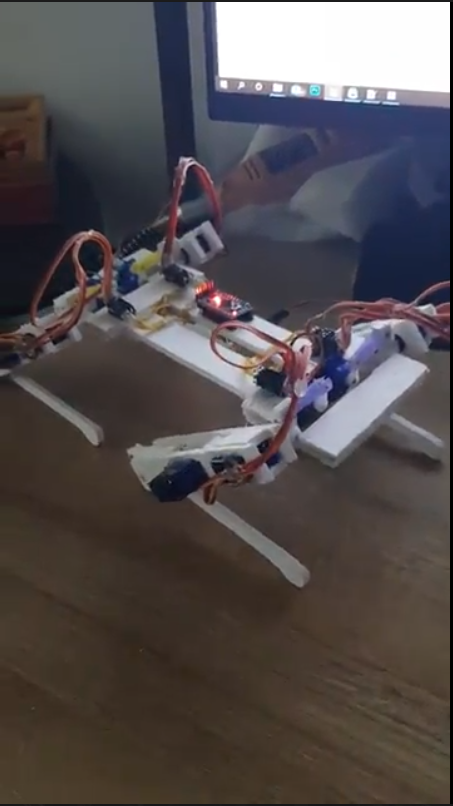
The third iteration of my quadruped robot platform, using a lightweight custom body, 9G servos and an Arduino Pro Mini for foundational motion.
 Robotics & Embedded Systems
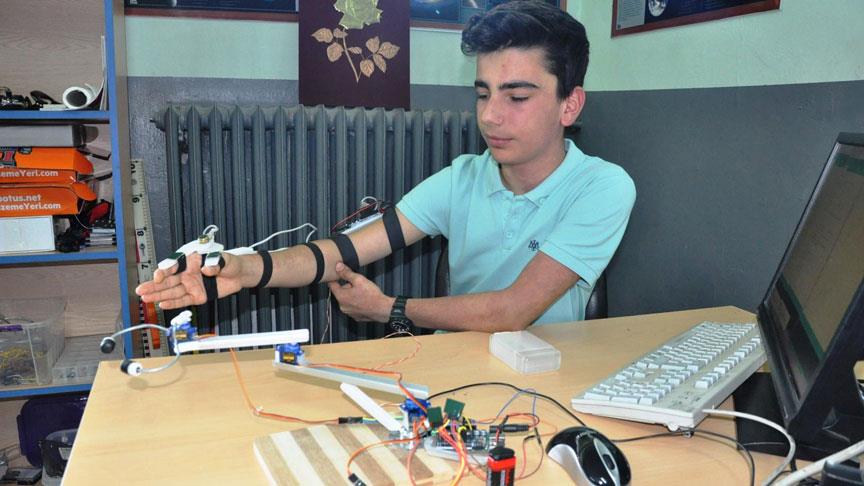
A remotely operated gripping robot arm controlled through a custom wearable interface and developed for a TÜBİTAK science fair.
 Robotics & Embedded Systems
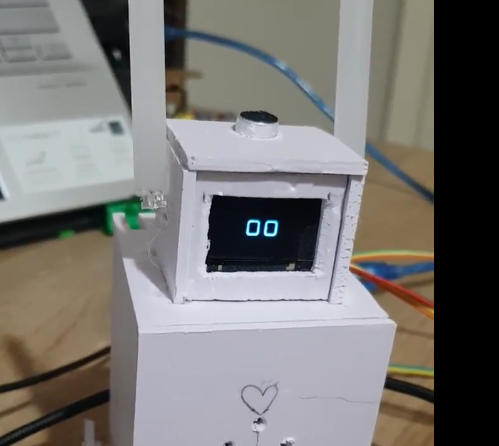
An interactive Arduino toy robot for children, combining independent movement, audio recording and animated facial expressions.
 Robotics & Embedded Systems
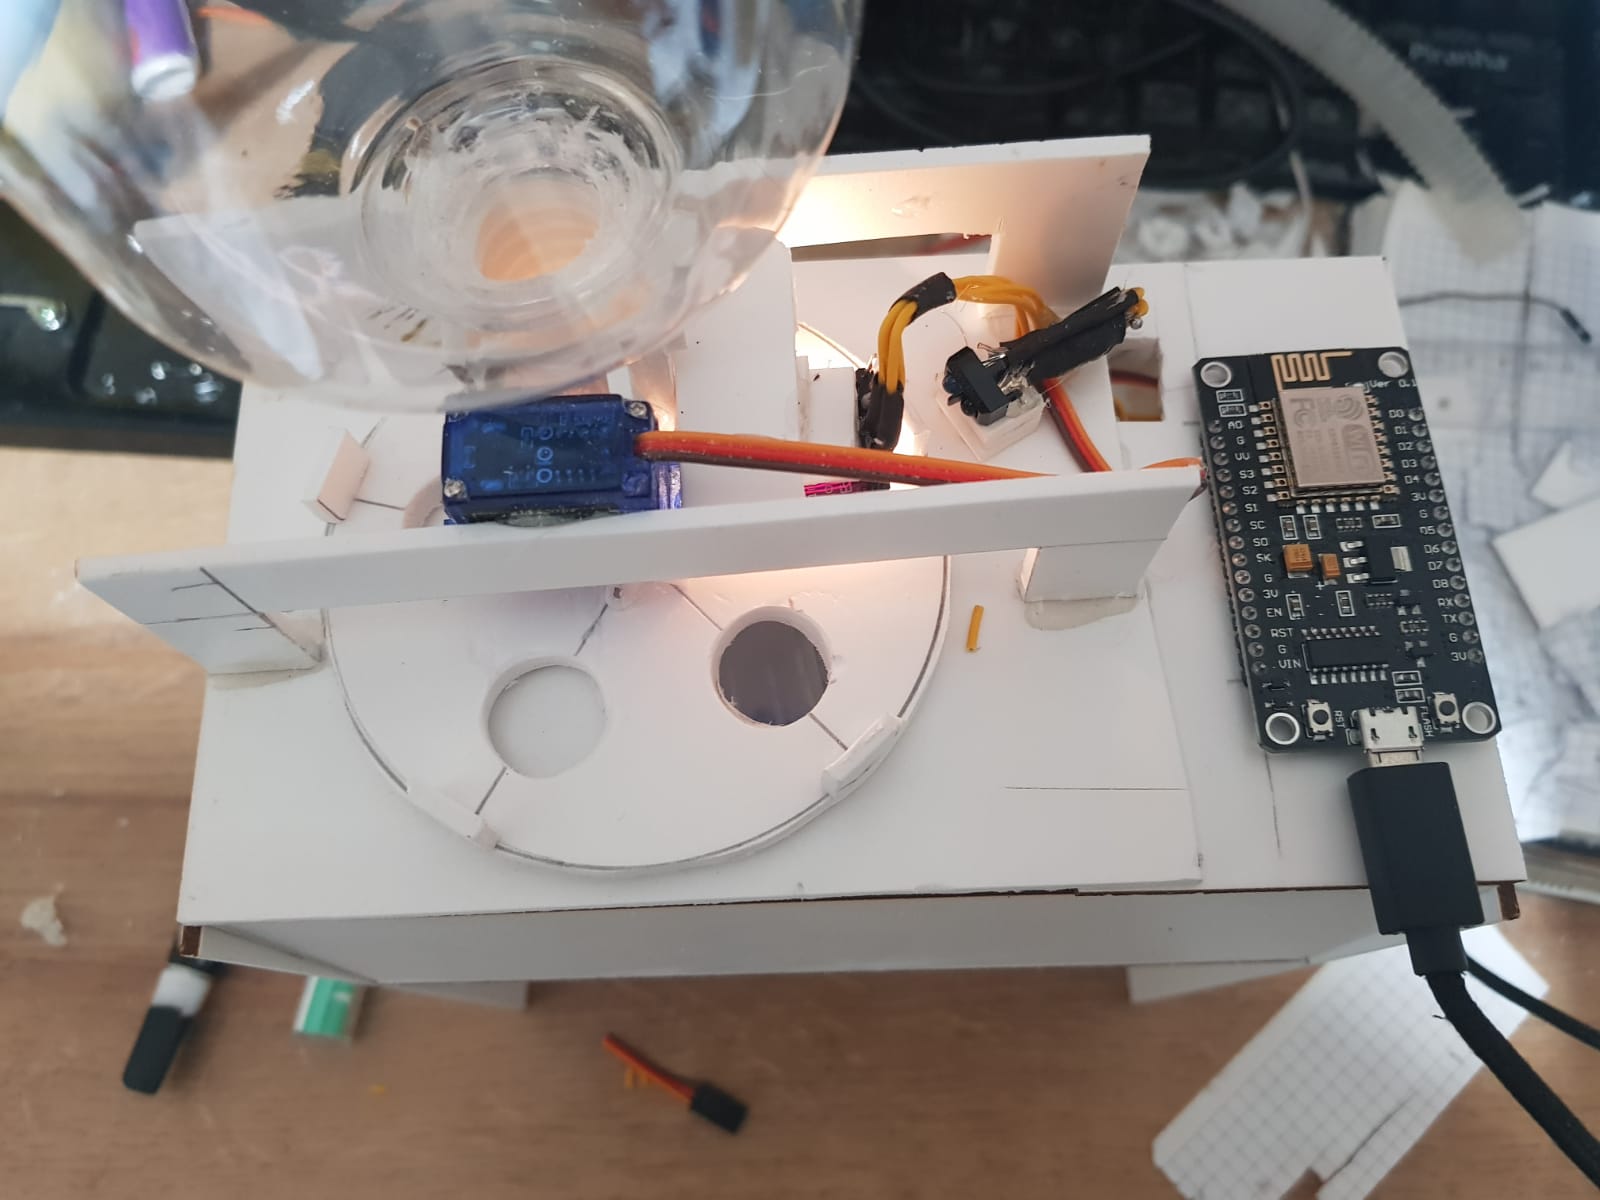
An ESP8266-controlled automation machine that detects colored objects and routes them into the correct compartments.
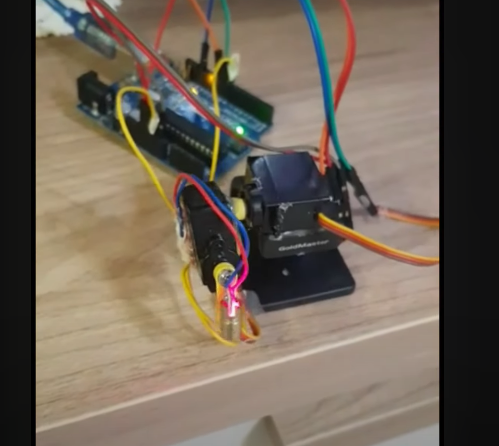 Robotics & Embedded Systems
An interactive pet-toy prototype using an ESP01, Arduino and two-axis servo control to move a laser remotely.